Relationships before pixels
The model works with named objects, observed distances, scale estimates, and explicit constraints before Blender produces an image.
Loading SOILIE-3D
Spatial cognition · procedural scenes · visual memory
From descriptive relations to a depictive scene.
SOILIE-3D explores a question: can measured relationships from observed rooms act as a compact spatial memory for constructing a place that has never existed?
Origin and intent
A small research model with a visible line of reasoning.
SOILIE-3D stands for Science of Imagination Lab Imagination Engine 3D. The project grew from the Science of Imagination Laboratory at Carleton University , where research includes visuospatial memory, reasoning, and imagined scenes.
SOILIE-3D examines a cognitively inspired procedural scene generator in which observations become explicit constraints, coordinates, and an inspectible room. It treats measurements from labelled RGB-D observations as a rough form of spatial memory, recombines recorded relationships, then tries to place familiar object classes into a new arrangement.
The system is deliberately explicit rather than a black-box image generator. Distances, object sizes, orientation rules, support relationships, boundaries, placement order, and uncertainty can all be inspected in the resulting scene data. These are cognitively inspired design hypotheses, not evidence that the engine duplicates human imagination.
The implementation keeps relationships, dimensions, placement choices, failures, and generated artifacts visible so the model can be reproduced, questioned, and changed.
The model works with named objects, observed distances, scale estimates, and explicit constraints before Blender produces an image.
Placement order, opacity, coordinates, anchors, and room dimensions expose how each proposal was assembled.
Unsupported object combinations and generation failures can be inspected alongside successful outputs. Optional room-size adjustments remain separate from model evaluation.
From recollection to reconstruction
Each stage turns observations into constraints, and constraints into a scene that can be examined rather than simply accepted.
Labelled RGB-D examples provide object identities, depth, and recurring distance and angle patterns in indoor scenes.
The engine turns those patterns into explicit distance, scale, orientation, boundary, support, and collision constraints.
The SOILIE-3D triplet sampler and Blender rule sequence produce an inspectible proposal, including the result data used to build it.
Four examples from the model
Each completed room sits beside its formation sequence. The camera turns toward new objects while earlier ones lose detail, brightness, colour, and opacity. Explore how the model constructs these scenes.
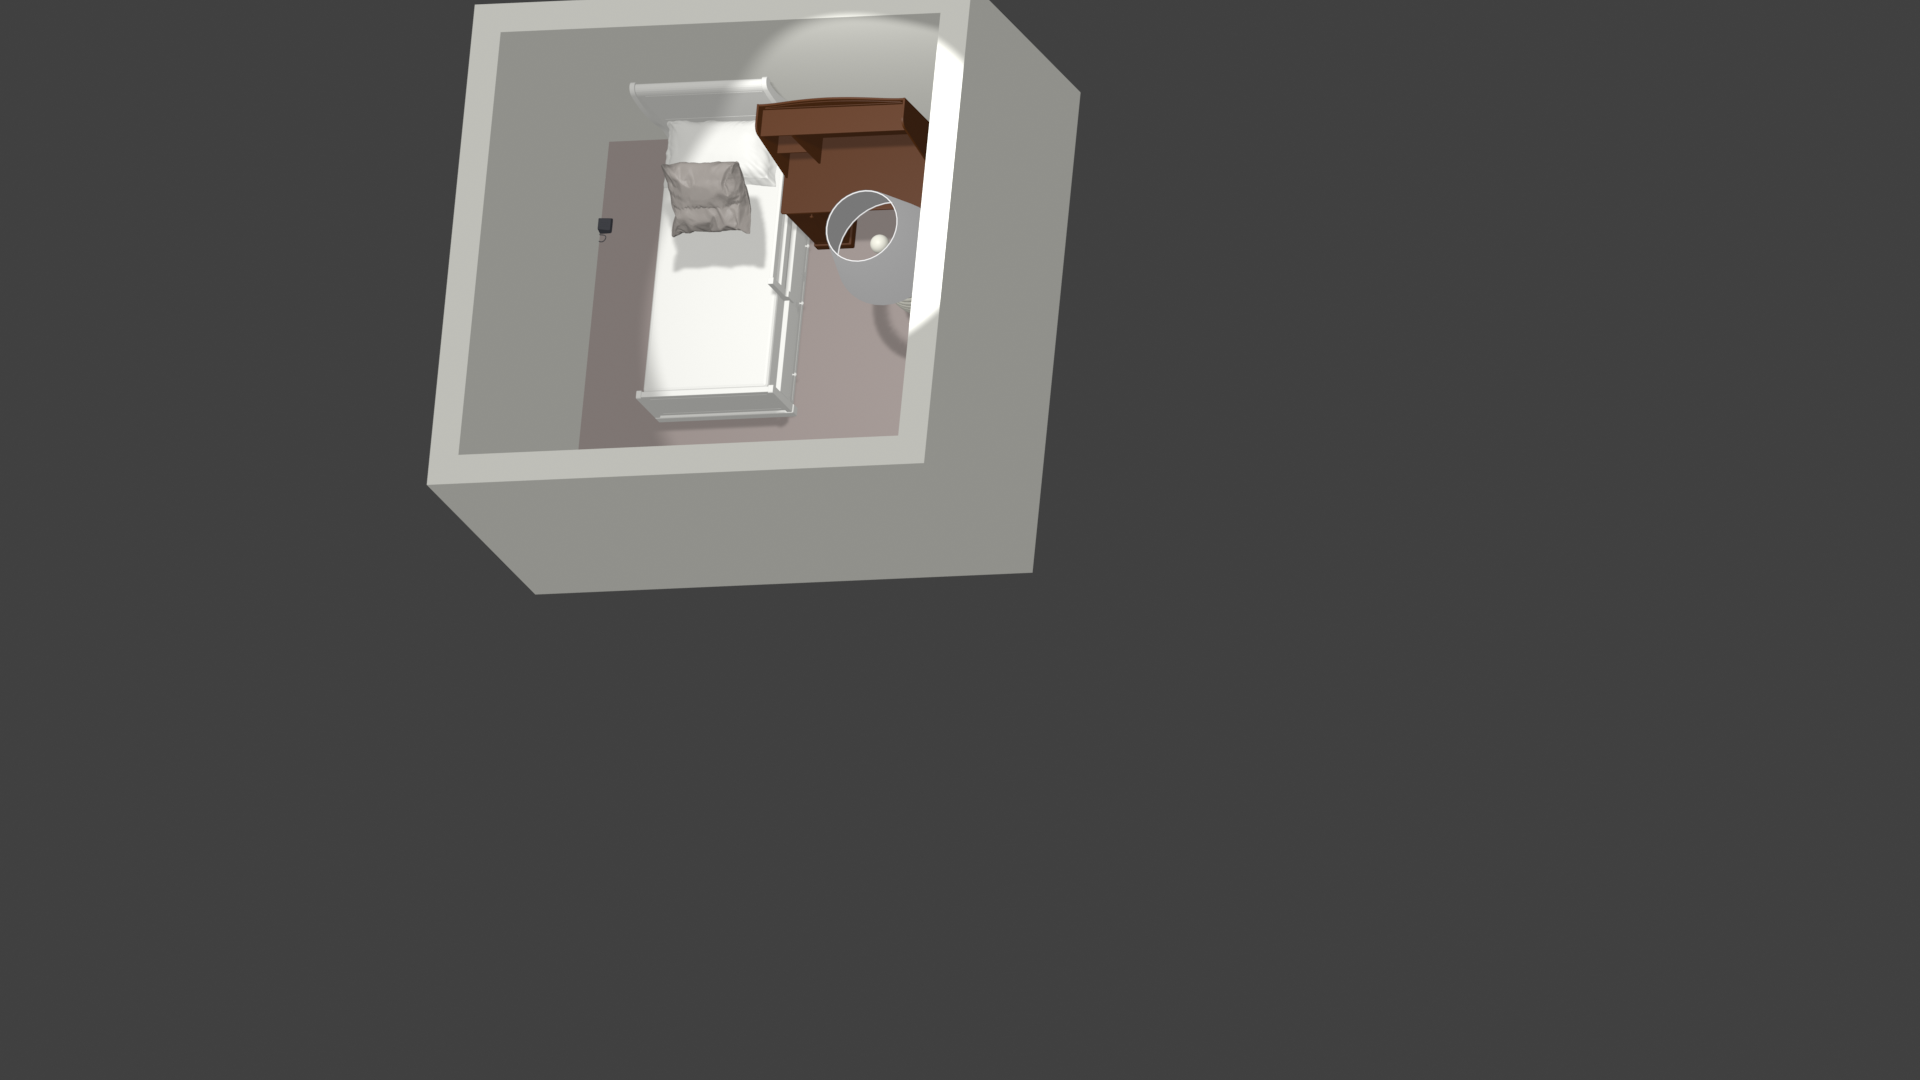
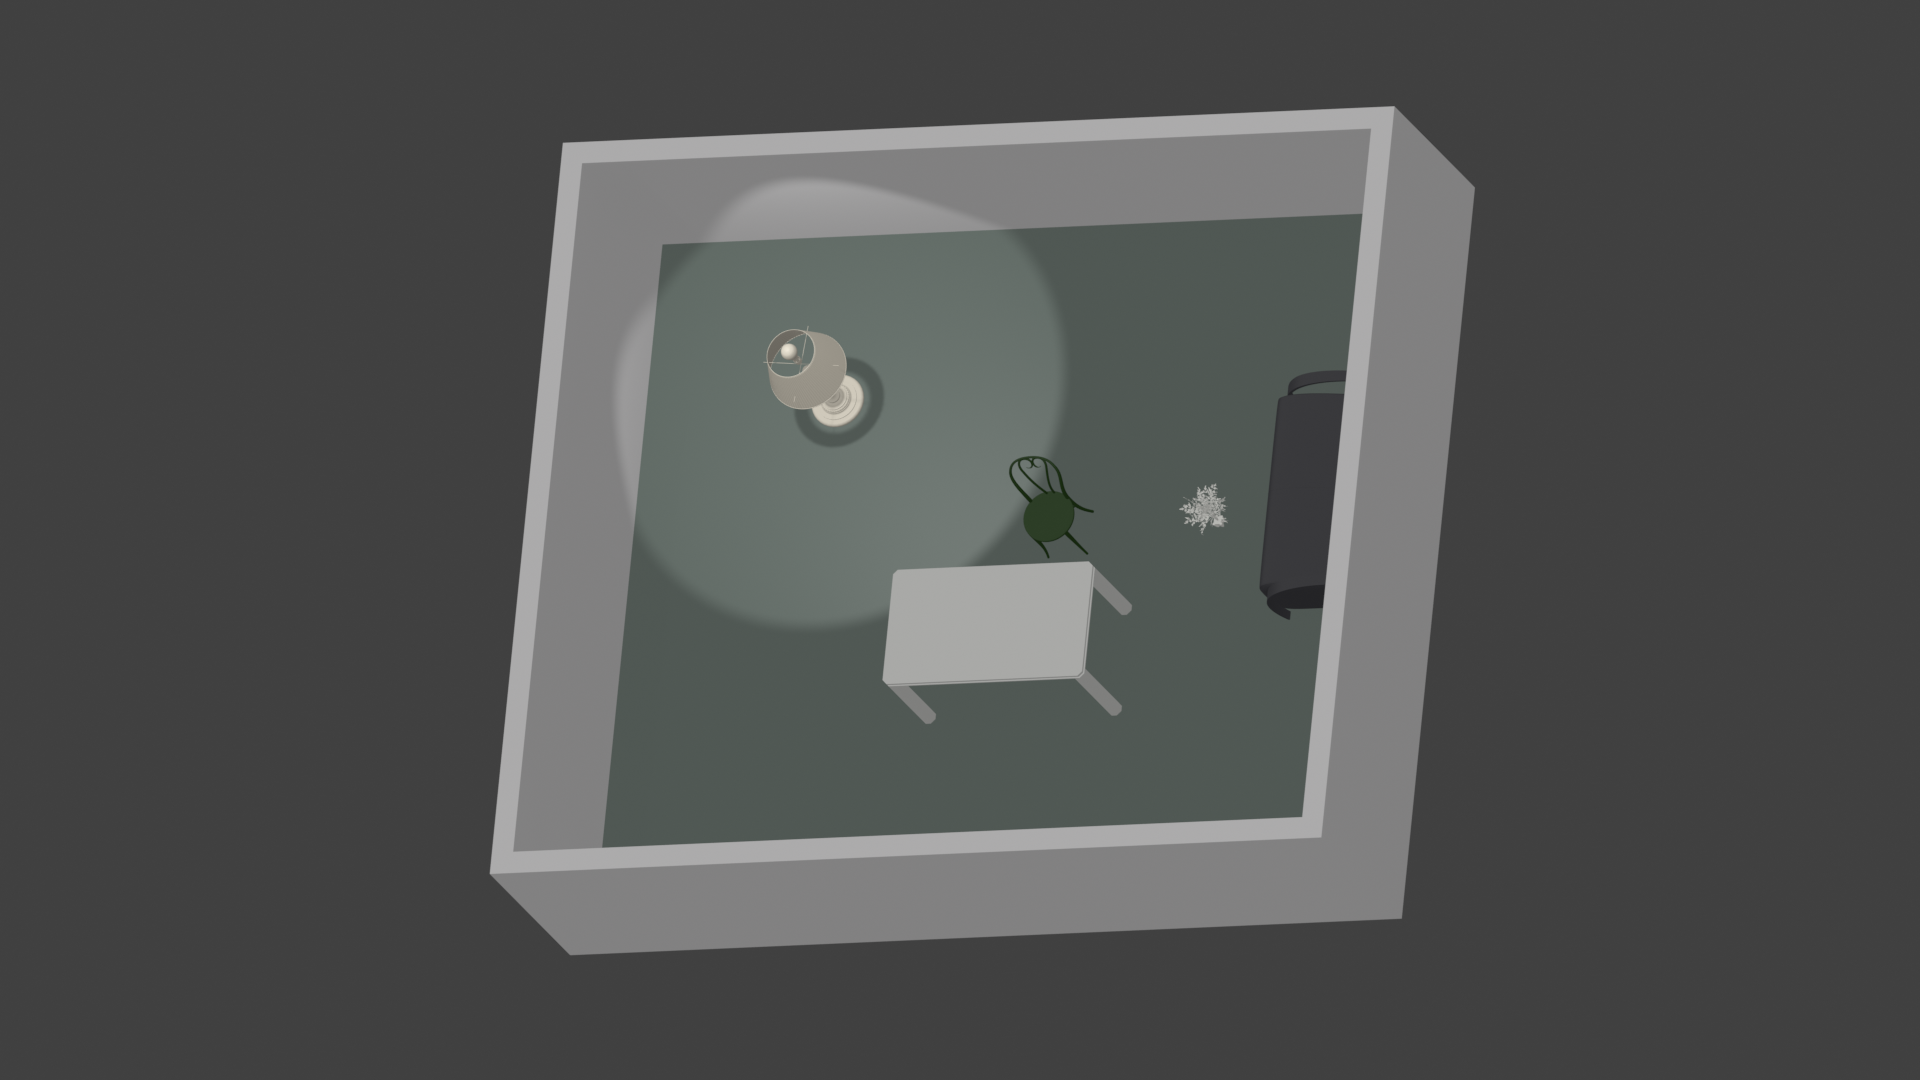
Animated previews are replaced with stills when your device requests reduced motion.
Open the research archive
Browse source assets, intermediate data, and generated outputs from this evolving research prototype. Generate a seeded scene, download its coordinates, then run the same request again.